
ABB SNAT-7120 Circuit Board – SNAZ7120J Series
ABB SNAT-7120 SNAZ 7120 J SNAZ7120J is listed for SNAZ7120J Series RFQ review. Confirm quantity, condition and destination before quotation.
RFQ-ready industrial model
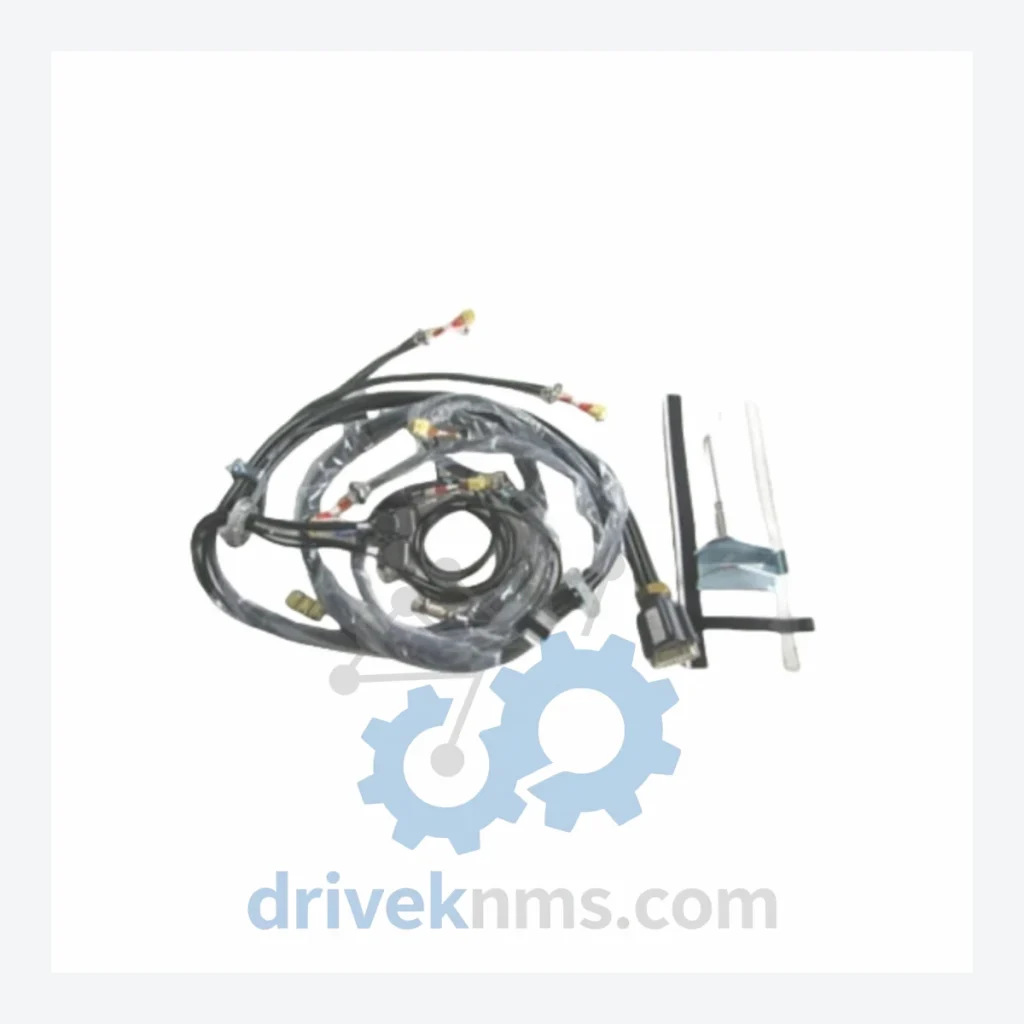
Model: 3HAC0233447-001
Product Overview
Commercial availability is handled through direct RFQ, model verification and export-oriented follow-up rather than public cart checkout.
Datasheet Preview
Use attached product manuals when available. If the manual is not public yet, request the full file directly through RFQ.
Commercial Path
Product pages on DRIVEKNMS are designed to verify model, brand and series first, then move the buyer into one clean quotation path.
Technical Dossier
ABB's internal robot cabling architecture has evolved through three distinct generations. The first generation (IRB 1400 / IRB 2400 early variants, 1990s–early 2000s) used discrete bundled cables routed through open cable trays within the robot arm, with individual connector terminations at each axis. This design was serviceable but prone to abrasion failure at axis 2 and axis 3 pivot points under high-cycle conditions.
The second generation introduced integrated harness assemblies — pre-routed, sheathed cable bundles that span multiple axes in a single replaceable unit. The 3HAC0233447-001 belongs to this generation, designed for the IRB 6600 / IRB 6640 platform. It routes signal, power, and brake control lines from axis 1 through axis 6 in a single trunk, reducing installation time and minimizing connector failure points. Compatibility is specific to the IRB 6640 frame geometry; it is not interchangeable with IRB 4400 or IRB 7600 harness assemblies without modification.
The third generation (IRB 6700 and later) transitioned to a fully enclosed dress package with modular sub-harness segments, allowing individual axis segment replacement without full harness removal. Facilities migrating from IRB 6640 to IRB 6700 must account for this architectural incompatibility when planning spare parts inventory.
The following SKUs represent verified components within the ABB IRB harness, cable, and axis drive ecosystem. Each entry reflects a distinct functional role within the robot's internal wiring architecture.
3HAC0233447-001: Axis 1-6 trunk harness assembly for IRB 6640; full signal and power routing
3HAC025338-001: Axis 1-3 lower arm harness for IRB 6640; brake and encoder signal bundle
3HAC025339-001: Axis 4-6 upper arm harness for IRB 6640; wrist signal and power sub-assembly
3HAC026610-001: Harness axis 1-6 for IRB 6600; predecessor to 3HAC0233447-001
3HAC028357-001: Cable harness axis 1-6 for IRB 4400; not interchangeable with IRB 6640 variant
3HAC031683-001: Axis 1-6 harness for IRB 2400/16; compact arm configuration
3HAC14550-1: Resolver cable axis 1 for IRB 6640; individual axis signal line
3HAC14551-1: Resolver cable axis 2 for IRB 6640; individual axis signal line
3HAC14552-1: Resolver cable axis 3 for IRB 6640; individual axis signal line
3HAC14553-1: Resolver cable axis 4 for IRB 6640; wrist resolver signal
3HAC14554-1: Resolver cable axis 5 for IRB 6640; wrist resolver signal
3HAC14555-1: Resolver cable axis 6 for IRB 6640; tool flange resolver signal
3HAC025917-001: Power cable axis 1-3 for IRB 6640; motor drive power supply bundle
3HAC025918-001: Power cable axis 4-6 for IRB 6640; upper arm motor drive power
3HAC026611-001: Brake cable assembly axis 1-6 for IRB 6600/6640; electromagnetic brake control
3HAC031030-001: SMB (Serial Measurement Board) cable for IRB 6640; encoder data bus
3HAC025340-001: Customer cable conduit axis 1-6 for IRB 6640; process media routing channel
3HAC028358-001: Harness axis 1-6 for IRB 7600; heavy payload variant, not compatible with IRB 6640
Harness assemblies for multi-axis industrial robots present specific quality verification challenges due to the combination of high-flex cable segments, multi-pin connector integrity, and shielding continuity requirements. DriveKNMS applies the following test protocol to all ABB IRB harness units prior to dispatch:
Continuity verification: Each conductor within the harness is tested end-to-end using a calibrated milliohm meter. Open circuits and high-resistance joints are flagged and rejected.
Insulation resistance test: Conducted at 500V DC between each conductor and shield ground. Minimum acceptable IR value: 100 MΩ. This identifies degraded insulation from heat cycling or chemical exposure.
Connector pin retention force: Each multi-pin connector is tested for pin retention using a calibrated pull gauge. Pins below OEM-specified retention force are replaced before assembly is approved.
Shield continuity: Braided and foil shields are verified for end-to-end continuity. Broken shield segments are a primary cause of resolver signal noise and axis fault codes on ABB IRC5 controllers.
Dimensional inspection: Harness routing geometry is verified against OEM reference drawings to confirm correct cable length, conduit diameter, and connector orientation for the target robot model.
Continue The Model Path
Move from this exact model into the matching system hub, brand archive, model-family archive or lifecycle sourcing route before sending a final RFQ list.
Related Paths
ABB SNAT-7120 SNAZ 7120 J SNAZ7120J is listed for SNAZ7120J Series RFQ review. Confirm quantity, condition and destination before quotation.
ABB PM564-TP-ETH 1SAP121100R0071 is listed for Servo Drives RFQ review. Confirm quantity, condition and destination before quotation.
ABB SCDCS-CON-4 is listed for CON-4 Control Board RFQ review. Confirm quantity, condition and destination before quotation.