Technical Dossier
Product Details And Specifications
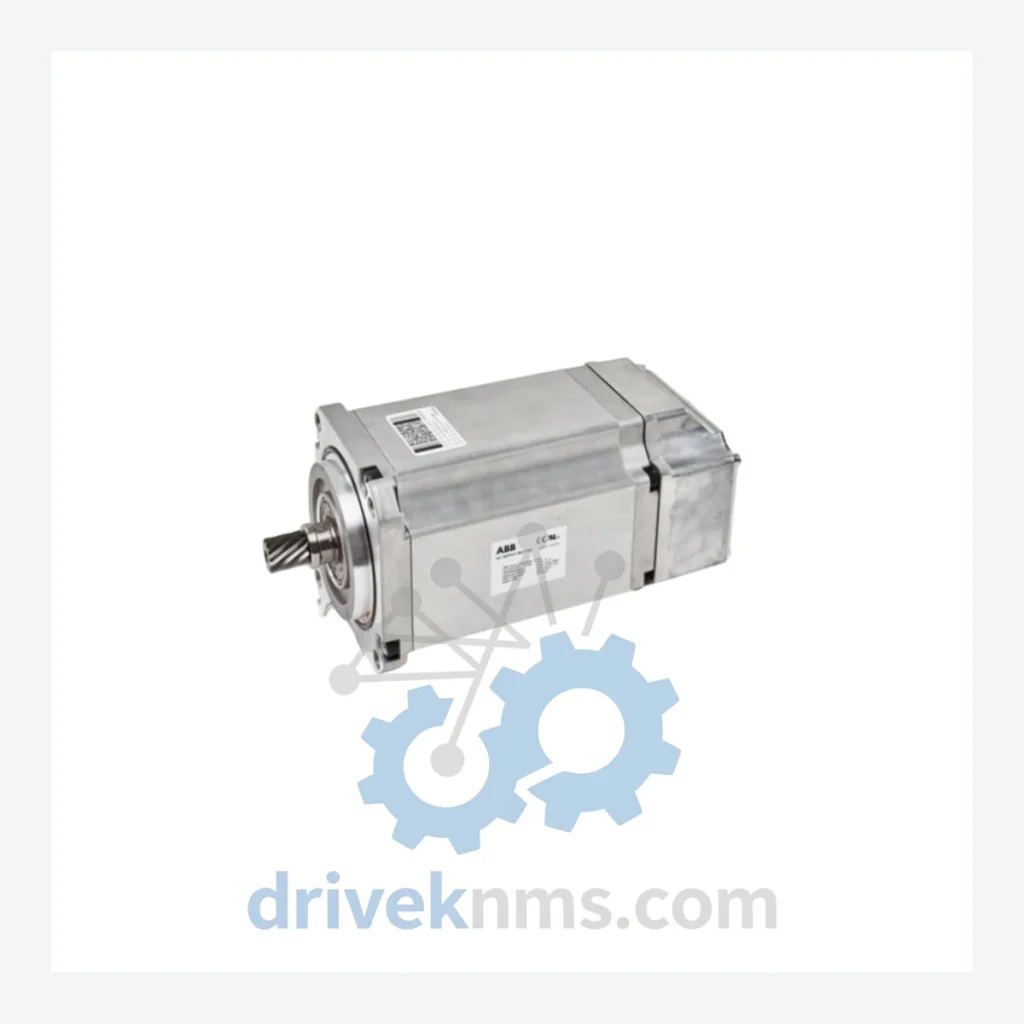
ABB 3HAC024518-004 Robot Motor incl Pinion – Obsolete IRB 6640 Spare Part
RFQ support for obsolete parts: Send the model number, required quantity and destination so DriveKNMS can confirm sourcing options before quotation.
Solving the Discontinued Hardware Crisis
The ABB IRB 6640 was a workhorse in heavy-payload automation — widely deployed in automotive body shops, foundries, and large-part handling lines throughout the 2000s and 2010s. Many of these installations remain in active production. The robot's mechanical structure is sound; the control architecture is stable. The only vulnerability is the availability of wear components, and the axis motor assemblies are at the top of that list.
The pinion-integrated motor design used in the IRB 6640 means that a motor failure is not a simple swap of a generic servo motor. The pinion mesh geometry, backlash specification, and encoder calibration are all tied to the specific assembly. Substituting an incompatible unit risks gearbox damage, axis calibration drift, and — in worst cases — a collision event that damages the robot arm itself. The only safe replacement is the correct OEM part number.
For plant engineering teams managing aging IRB 6640 fleets, the strategic calculus is straightforward: the cost of holding one or two spare motor assemblies is a fraction of the cost of a single unplanned stoppage, and an order of magnitude less than a forced platform migration. DriveKNMS exists specifically to serve this gap — sourcing, verifying, and holding inventory of parts that OEM channels no longer supply.
Extending Asset Life by 5–10 Years: A Maintenance Strategy for IRB 6640 Operators
Factory management teams facing pressure to retire aging robot cells often underestimate the true cost of replacement versus the cost of structured maintenance. The following approach has allowed operators to extend IRB 6640 service life by five to ten years without compromising throughput or safety:
1. Conduct a criticality audit of all axis motors. Identify which axes carry the highest duty cycle and payload stress. On the IRB 6640, axes 1, 2, and 3 bear the greatest mechanical load and are the most likely candidates for motor wear. Prioritize spare holding for these positions.
Q: How are RFQ terms confirmed?
A: Quantity, required condition, documentation needs, destination and sourcing route are confirmed during RFQ review before quotation.
4. Maintain firmware and calibration records. When replacing a motor assembly, document the axis calibration parameters before removal. This eliminates re-calibration time and reduces the risk of introducing positioning errors after the swap.
5. Secure obsolete spares before inventory is exhausted. The global supply of discontinued ABB motor assemblies is finite and shrinks with every repair event worldwide. Procurement decisions made today determine whether parts are available in two years. Waiting until a failure occurs is the highest-risk procurement strategy available.
Condition & Reliability Assurance
Every motor assembly shipped by DriveKNMS passes a five-stage inspection protocol before release:
- Stage 1 – Electrolytic Capacitor Assessment: Capacitors in stored motor drive components are subject to electrolyte degradation over time. Each unit is inspected for capacitor bulge, leakage, and ESR deviation. Units with suspect capacitors are either reconditioned or rejected.
- Stage 2 – Firmware Version Verification: Where applicable, embedded firmware versions are confirmed against the compatibility matrix for the IRB 6640 controller. Mismatched firmware can cause axis faults that are difficult to diagnose in the field.
- Stage 3 – Connector and Pin Inspection: All electrical connectors are inspected under magnification for pin corrosion, fretting wear, and mechanical deformation. Corroded contacts are the leading cause of intermittent faults in stored components.
- Stage 4 – Mechanical Integrity Check: The pinion gear teeth are inspected for chipping, pitting, and abnormal wear patterns. Shaft runout is measured where test equipment permits.
- Stage 5 – Functional Verification: Where test bench capability exists, the motor is energized and rotation, encoder signal integrity, and thermal behavior are verified prior to packaging.
Key Features for System Maintenance
- Drop-in replacement: This is the correct OEM part number for the IRB 6640. No mechanical modification, no wiring adaptation, and no re-programming of the robot controller is required. The replacement procedure follows the standard ABB service manual.
- No engineering rework: Unlike cross-brand substitutions or custom-adapted motors, this assembly preserves the original kinematic parameters of the robot. There is no need to engage a robotics integrator or modify safety zone configurations.
- Avoids platform migration cost: Keeping an IRB 6640 cell operational with OEM spare parts costs a fraction of migrating to a current-generation robot — even accounting for the premium on obsolete part sourcing.
- Documented provenance: DriveKNMS provides documentation of part origin and inspection status with each shipment, supporting your internal maintenance records and audit requirements.
Q: How is condition confirmed before quotation?
A: Available condition, photos, test records and documentation are checked according to the requested model and sourcing channel before a formal RFQ response.
Q: Can you support multi-unit or repeat RFQ requests?
A: Yes. Send the model list, target quantity and destination so DRIVEKNMS can review sourcing options and quote the requirement as a project RFQ.
Q: Do you support international shipping?
A: Yes. DriveKNMS ships globally. Export documentation, commercial invoices, and packing lists are provided as standard. Contact us for freight options to your location.