
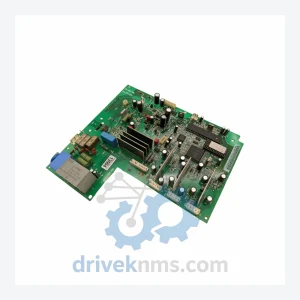
ABB SNAT-7120 Circuit Board – SNAZ7120J Series
ABB SNAT-7120 SNAZ 7120 J SNAZ7120J is listed for SNAZ7120J Series RFQ review. Confirm quantity, condition and destination before quotation.
RFQ-ready industrial model
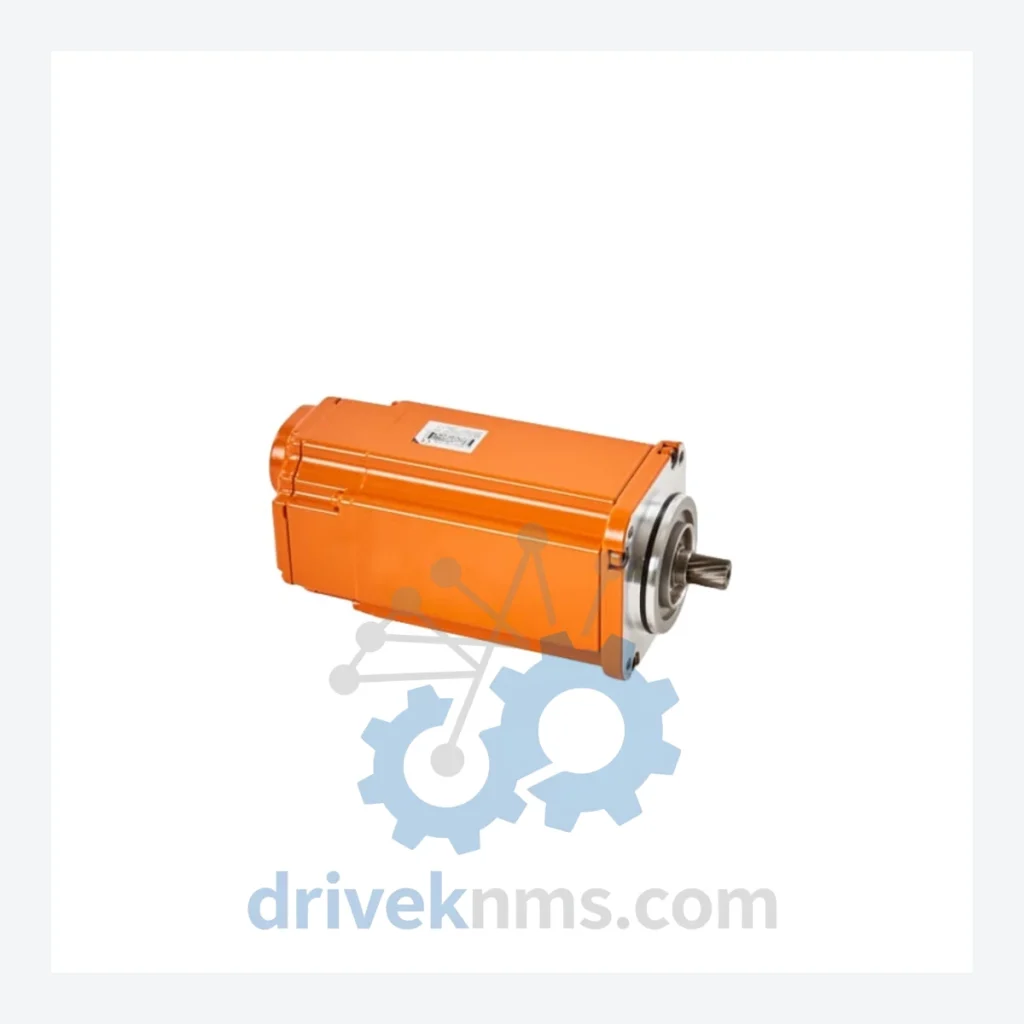
Model: 3HAC057551-003 IRB6650S 3HAC040500-001 lRB460. 3HAC055547-003 lRB6650S
Product Overview
Commercial availability is handled through direct RFQ, model verification and export-oriented follow-up rather than public cart checkout.
Datasheet Preview
Use attached product manuals when available. If the manual is not public yet, request the full file directly through RFQ.
Commercial Path
Product pages on DRIVEKNMS are designed to verify model, brand and series first, then move the buyer into one clean quotation path.
Technical Dossier
RFQ support for obsolete parts: Send the model number, required quantity and destination so DriveKNMS can confirm sourcing options before quotation.
Note: Electrical parameters such as rated torque, encoder resolution, and voltage ratings are model-specific and will be confirmed upon inquiry. DriveKNMS does not publish unverified specifications.
The ABB IRB6650S is a high-payload articulated robot deployed extensively in automotive body-in-white welding, press tending, and heavy material handling. Its servo motors — particularly the 3HAC057551-003 on the primary axes — are precision-matched to the IRC5 drive system. The IRC5 controller communicates with these motors through a proprietary resolver and feedback protocol that is not forward-compatible with ABB's current OmniCore platform.
This creates a hard boundary: if your facility runs IRC5-based cells, you cannot simply install a current-generation motor and resume production. The drive parameters, safety monitoring thresholds, and axis calibration data are all tied to the original hardware specification. Replacing the controller to accommodate a modern motor requires full cell re-engineering — a project measured in months, not days.
How to extend your IRC5 robotic assets by 5–10 years without a capital replacement program:
Discontinued servo motors present specific failure risks that differ from standard wear items. DriveKNMS applies a 5-stage inspection protocol to every unit before it leaves our facility:
Q: How do I confirm the unit is genuine ABB and not a counterfeit?
A: Every unit shipped by DriveKNMS includes documentation of its inspection record and, where available, original ABB packaging and labeling. We do not source from unverified brokers. Customers may request pre-shipment photos of the specific unit reserved for their order.
Continue The Model Path
Move from this exact model into the matching system hub, brand archive, model-family archive or lifecycle sourcing route before sending a final RFQ list.
Related Paths
ABB SNAT-7120 SNAZ 7120 J SNAZ7120J is listed for SNAZ7120J Series RFQ review. Confirm quantity, condition and destination before quotation.
ABB PM564-TP-ETH 1SAP121100R0071 is listed for Servo Drives RFQ review. Confirm quantity, condition and destination before quotation.
ABB SCDCS-CON-4 is listed for CON-4 Control Board RFQ review. Confirm quantity, condition and destination before quotation.