
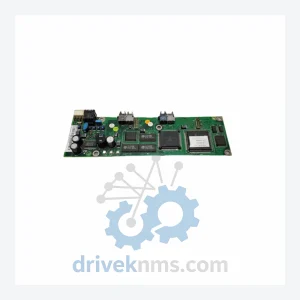
ABB NAMC-11C
ABB NAMC-11C is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.
RFQ-ready industrial model
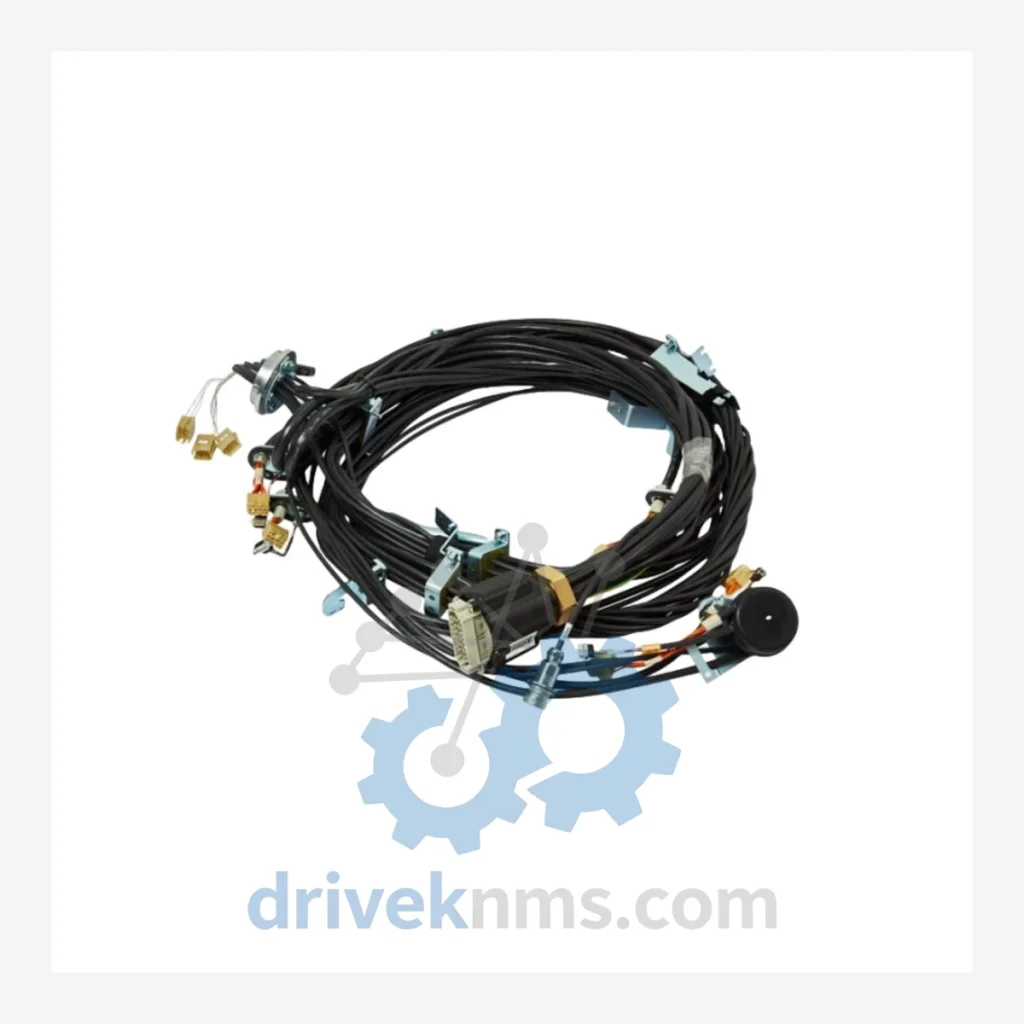
Model: 3HAC10828-10 IRB66xx 3HNA024855-001MCB-02B 3HAC024386-001¢ñRB6640.lRB6600
Product Overview
Commercial availability is handled through direct RFQ, model verification and export-oriented follow-up rather than public cart checkout.
Datasheet Preview
Use attached product manuals when available. If the manual is not public yet, request the full file directly through RFQ.
Commercial Path
Product pages on DRIVEKNMS are designed to verify model, brand and series first, then move the buyer into one clean quotation path.
Technical Dossier
The ABB IRB6600 and IRB6640 are high-payload industrial robot series deployed across heavy-industry sectors including automotive body-in-white assembly, chemical plant material handling, nuclear facility maintenance robotics, and refinery process automation. With payload ratings of 175–205 kg and reach envelopes of 2.55–2.8 m, these platforms represent ABB's mature 6-axis heavy-duty articulated robot architecture. The manipulator harness assembly — routing power, signal, and pneumatic lines through axes 1–6 — is a critical wear component with a defined replacement interval. Global installed base for the IRB6600/6640 family runs into tens of thousands of units, making harness availability a tier-1 spare parts priority for plant maintenance teams worldwide.
ABB introduced the IRB6600 platform in the early 2000s as a successor to the IRB6400 series, adopting a parallel-arm upper-arm design to increase stiffness and payload capacity. The harness architecture evolved across three identifiable generations:
Generation 1 (IRB6600 — 2001–2006): Single-trunk harness routed externally along the upper arm. Part numbers in the 3HAC10xxx range. Compatible with S4C+ and IRC5 controllers in early configurations. Primary failure modes: abrasion at axis-3 bend radius and connector fretting at the wrist.
Generation 2 (IRB6600 / IRB6640 — 2006–2012): Revised internal routing through the upper arm casting. Introduction of the 3HNA024855-001 MCB sub-harness for integrated media flange compatibility. Improved strain-relief boots at axes 4 and 5. IRC5 controller standard.
Generation 3 / Current (IRB6640 — 2012–present): Modular harness segments allowing axis-specific replacement without full harness pull. Part numbers in the 3HAC024386-001 range. Compatible with IRC5 and OmniCore C90XT in retrofit configurations. ABB has confirmed continued spare parts availability through at least 2030 under its long-term service program.
Compatibility note: IRB6600 and IRB6640 harnesses share the same axis-1-to-3 trunk geometry but differ at the upper-arm connector block. Cross-referencing by robot serial number prefix (6600-xxx vs. 6640-xxx) is mandatory before ordering.
The following SKUs represent the verified harness and cable assembly catalog for the IRB6600 and IRB6640 series. Each entry reflects a discrete functional assembly. Substitution between part numbers requires ABB service bulletin confirmation.
3HAC10828-10: Complete manipulator harness, axes 1–6, IRB6600/6640, standard reach variant — primary replacement assembly covering full cable trunk from base to wrist.
3HNA024855-001MCB-02B: Media cabinet sub-harness, axis-1 interface board connector assembly — routes I/O and fieldbus signals from IRC5 cabinet to robot base.
3HAC024386-001: Upper-arm harness segment, axes 4–6, IRB6640 — modular wrist-side cable assembly for axis-specific replacement without full harness removal.
3HAC028357-001: Axis-1 motor power cable, IRB6600/6640 — high-flex shielded cable, 2.5 mm² conductors, rated for 10 million flex cycles.
3HAC028358-001: Axis-2 motor power cable, IRB6600/6640 — identical specification to axis-1 cable; routed through lower-arm casting.
3HAC028359-001: Axis-3 motor power cable, IRB6600/6640 — includes extended strain-relief boot for high-cycle bend radius at axis-3 pivot.
3HAC028360-001: Axis-4 motor power cable, IRB6640 — upper-arm internal routing; requires upper-arm cover removal for replacement.
3HAC028361-001: Axis-5 motor power cable, IRB6640 — wrist-side cable; routed through wrist housing; compatible with standard and foundry wrist variants.
3HAC028362-001: Axis-6 motor power cable, IRB6640 — shortest segment; high-flex construction for continuous rotation applications.
3HAC14550-1: Signal harness, axes 1–3, IRB6600 — resolver and brake signal routing for lower-arm axes; Gen-1 architecture.
3HAC14551-1: Signal harness, axes 4–6, IRB6600 — upper-arm resolver and brake signals; Gen-1 architecture; not interchangeable with IRB6640 upper-arm harness.
3HAC025338-001: Pneumatic hose bundle, axes 1–6, IRB6640 — 4× 6 mm OD polyurethane tubes routed alongside electrical harness for process media delivery.
3HAC025339-001: Ethernet/DeviceNet signal cable, axis-1 base connector — fieldbus extension for IRC5 EtherNet/IP or DeviceNet process I/O.
3HAC031683-001: Harness protective conduit kit, IRB6640 — replacement corrugated conduit and clamp set for external harness sections at axes 1–3.
3HAC044168-001: Wrist harness assembly, IRB6640 foundry plus variant — IP67-rated connector block and cable assembly for wash-down and high-contamination environments.
3HAC044169-001: Base connector plate assembly, IRB6640 — includes M23 circular connectors for power and signal; replacement unit for damaged base interface.
3HAC052982-001: Complete harness kit, IRB6640-185/2.8 — long-reach variant harness with extended cable lengths for 2.8 m reach configuration.
Manipulator harnesses for the IRB6600/6640 series present specific test challenges due to the combination of high-flex power conductors, low-voltage resolver signals, and fieldbus data lines routed in a common trunk. DriveKNMS applies the following test protocol to all harness assemblies prior to dispatch:
Continuity and insulation resistance: Each conductor tested end-to-end at 500 VDC megohm test. Minimum acceptable insulation resistance: 100 MΩ. Shields verified for continuity and isolation from conductors.
Connector inspection: M23 and M17 circular connectors inspected under 10× magnification for pin deformation, corrosion, and seal integrity. Connector retention force tested against ABB specification (minimum 45 N extraction force).
Flex fatigue assessment: Harnesses sourced from used equipment are inspected at the axis-3 and axis-5 bend radii — the two highest-cycle flex points — using fiber-optic borescope where conduit routing prevents direct visual access.
Functional validation: Where test fixtures are available, harness assemblies are energized through an IRC5 controller simulator to verify resolver signal integrity (amplitude and phase) and brake release function on all six axes.
Documentation: Each dispatched assembly is accompanied by a test record including continuity data, insulation resistance values, and inspector sign-off. Traceability to source robot serial number is maintained where available.
Continue The Model Path
Move from this exact model into the matching system hub, brand archive, model-family archive or lifecycle sourcing route before sending a final RFQ list.
Related Paths
ABB NAMC-11C is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.
ABB LZ02 is listed for H&B Contronic LZ Series RFQ review. Confirm quantity, condition and destination before quotation.
ABB LL02 is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.