
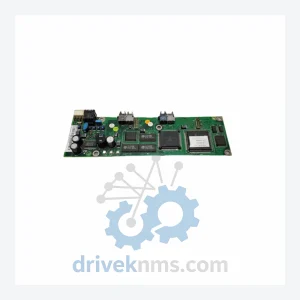
ABB NAMC-11C
ABB NAMC-11C is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.
RFQ-ready industrial model
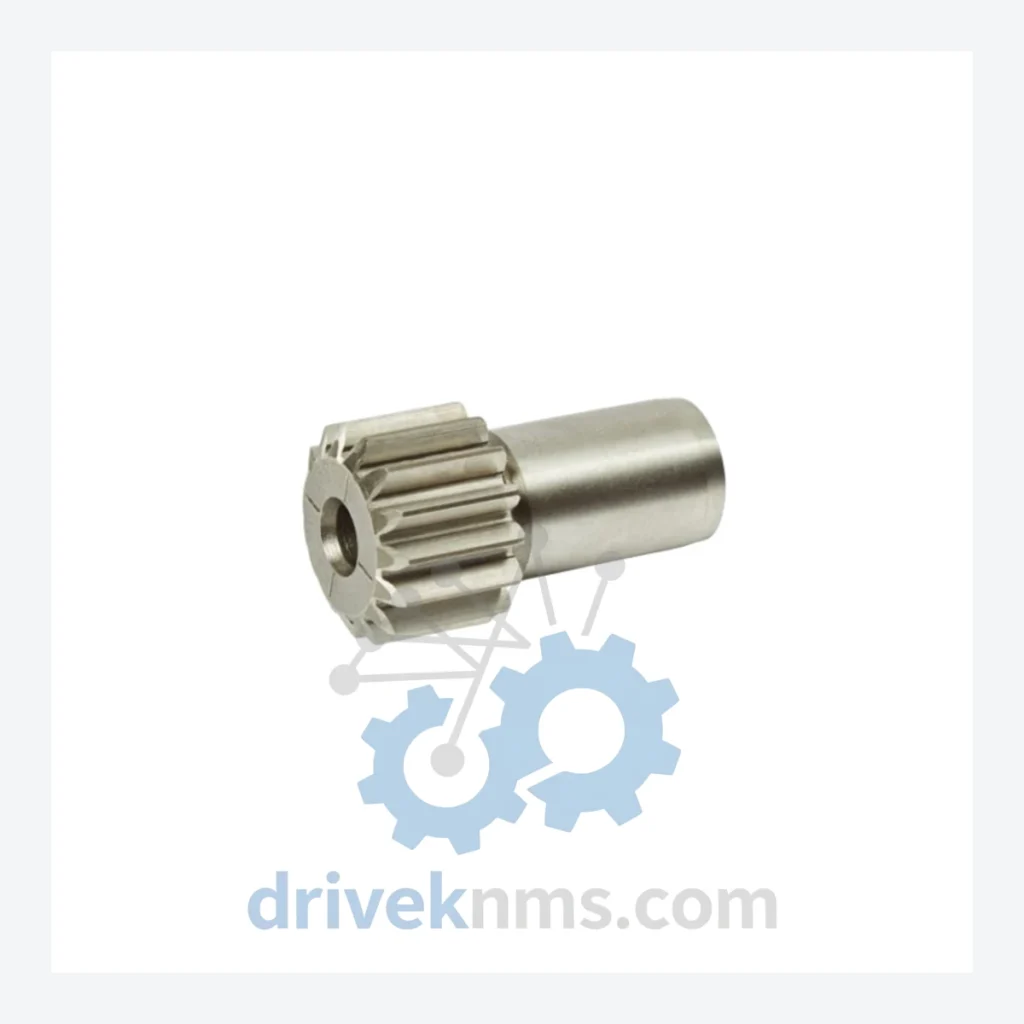
Model: 3HNA011788-001 3HAC057431-001 IRB6700 3HAC043074-001 3HAC043074-002
Product Overview
Commercial availability is handled through direct RFQ, model verification and export-oriented follow-up rather than public cart checkout.
Datasheet Preview
Use attached product manuals when available. If the manual is not public yet, request the full file directly through RFQ.
Commercial Path
Product pages on DRIVEKNMS are designed to verify model, brand and series first, then move the buyer into one clean quotation path.
Technical Dossier
Q: How are RFQ terms confirmed?
A: Quantity, required condition, documentation needs, destination and sourcing route are confirmed during RFQ review before quotation.
RFQ support for obsolete parts: Send the model number, required quantity and destination so DriveKNMS can confirm sourcing options before quotation.
The ABB IRB6700 is a high-payload articulated robot deployed across automotive body-in-white lines, heavy fabrication cells, and foundry automation. Its RV-series gearbox architecture — while mechanically robust — relies on precision-ground pinion components that are not interchangeable across generations. When ABB discontinues a mechanical sub-component like the 3HNA011788-001, the downstream consequence is not theoretical: a worn or fractured pinion produces axis positioning error, triggers SafeMove faults, and ultimately forces an unplanned cell shutdown.
DriveKNMS applies a 5-step inspection protocol to all discontinued mechanical and electromechanical components before dispatch review:
The pressure to retire aging robot fleets is rarely driven by mechanical failure alone. It is driven by parts unavailability. When a robot cannot be repaired because the required component no longer exists in any supply channel, the decision to replace is forced — regardless of the robot's remaining structural life. This is the core vulnerability of facilities that do not maintain a proactive spare parts inventory for discontinued components.
Q: Is this part compatible with all IRB6700 variants?
A: The 3HNA011788-001 is associated with the IRB6700 series. Compatibility with specific payload and reach variants should be confirmed against your robot's serial number and axis configuration before ordering. Our technical team can assist with cross-reference verification.
Continue The Model Path
Move from this exact model into the matching system hub, brand archive, model-family archive or lifecycle sourcing route before sending a final RFQ list.
Related Paths
ABB NAMC-11C is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.
ABB LZ02 is listed for H&B Contronic LZ Series RFQ review. Confirm quantity, condition and destination before quotation.
ABB LL02 is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.