Technical Dossier
Product Details And Specifications
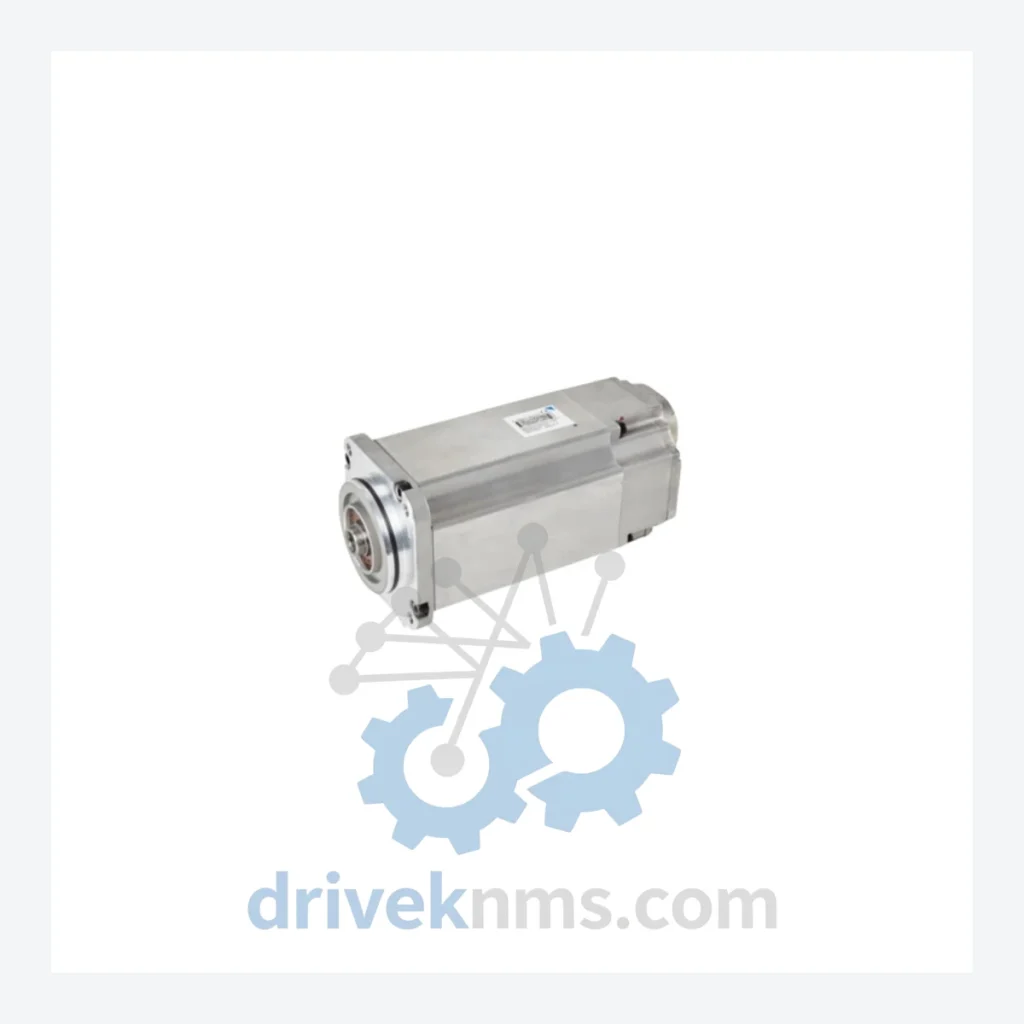
ABB 3HNE00278-1 Motor with Pinion – Obsolete IRB Series Spare Part
RFQ support for obsolete parts: Send the model number, required quantity and destination so DriveKNMS can confirm sourcing options before quotation.
Technical Specifications
| Part Number | 3HNE00278-1 |
| Paired Part Number | 3HNE00279-1 |
| Manufacturer | ABB Robotics |
| Series | IRB (Industrial Robot Series) |
| Component Type | Servo Motor with Pinion Gear Assembly |
| Gear Ratio Reference | 1600-6 / 1.45 |
| Production Status | Discontinued – No longer manufactured by ABB |
| Country of Origin | Sweden |
| Compatible Systems | ABB IRB robot series with S4, S4C, S4C+ controller generations |
Note: Electrical parameters such as rated voltage, current, and encoder resolution are not published here to prevent misapplication. Please contact our technical team for specification verification before ordering.
Solving the Discontinued Hardware Crisis
ABB's IRB robot platforms equipped with S4 and S4C+ controllers represent a generation of industrial automation that many facilities have operated for 15 to 25 years. The motion control architecture in these systems — including the axis motor assemblies identified by 3HNE00278-1 and 3HNE00279-1 — was engineered to tight mechanical tolerances specific to that robot generation. There is no direct cross-reference to current ABB GoFa or YuMi platforms. A failed motor assembly does not simply mean ordering a newer equivalent; it means either sourcing the original part or committing to a full robot cell replacement.
Extending Automation Asset Life by 5–10 Years: A Maintenance Strategy for Legacy ABB Robot Fleets
Facilities managing ABB IRB robots with S4C or S4C+ controllers face a predictable set of failure modes as these systems age past the 15-year mark. The following maintenance approach has been applied successfully to extend operational life by 5 to 10 years without full platform replacement:
1. Axis Motor Condition Monitoring: Implement quarterly vibration analysis on all axis motors. Early-stage bearing wear in motor assemblies like 3HNE00278-1 produces characteristic frequency signatures 3 to 6 months before catastrophic failure. Catching this early converts an emergency replacement into a planned maintenance event.
3. Controller Battery and Capacitor Management: S4C+ controllers use battery-backed memory for program retention. Replace controller batteries on a fixed 2-year cycle regardless of low-battery warnings. Capacitor degradation in the drive modules is a separate failure mode — inspect drive capacitors every 3 years and replace proactively.
4. Firmware Version Locking: Do not apply firmware updates to S4C+ controllers unless a specific fault requires it. Firmware changes on legacy controllers have caused axis calibration drift and, in some cases, incompatibility with existing motor assemblies. Document the current firmware version and treat it as a controlled configuration item.
5. Mechanical Backlash Auditing: The pinion gear assembly in 3HNE00278-1 is subject to wear-induced backlash over time. Measure and record axis backlash values annually. When backlash exceeds the manufacturer's tolerance band, replacement of the motor-pinion assembly is required. Delaying this replacement accelerates wear on the gearbox, converting a motor replacement into a gearbox replacement — a significantly more expensive intervention.
Condition & Reliability Assurance
All 3HNE00278-1 units supplied by DriveKNMS pass a structured 5-step inspection protocol before dispatch review:
Step 1 – Electrolytic Capacitor Assessment: Internal capacitors are inspected for bulging, leakage, and ESR degradation. Units with capacitor anomalies are either reconditioned with verified-specification replacements or rejected from inventory.
Step 2 – Firmware Version Verification: Where applicable, embedded firmware versions are documented and confirmed against the unit's original production batch records.
Step 3 – Pin and Connector Corrosion Inspection: All electrical connectors and motor terminals are inspected under magnification for oxidation, pin deformation, and contact resistance anomalies. Corroded contacts are treated or the unit is rejected.
Step 4 – Mechanical Integrity Check: The pinion gear assembly is inspected for tooth wear, shaft runout, and bearing play. Units outside tolerance are not shipped.
Step 5 – Functional Burn-In (where test equipment permits): Units are energized and monitored for abnormal current draw, encoder signal integrity, and thermal behavior before packaging.
Units are packaged in anti-static, moisture-barrier packaging with desiccant inserts for long-term storage compatibility.
Key Features for System Maintenance
The 3HNE00278-1 motor-with-pinion assembly is a direct mechanical and electrical replacement for the original ABB IRB axis position. Installation does not require robot reprogramming, axis recalibration software licenses, or controller hardware changes. The assembly mounts to the original mechanical interface and connects to the existing cable harness without modification.
This drop-in replacement characteristic is the critical operational advantage. Engineering labor for a motor swap on a familiar platform is measured in hours, not days. By contrast, a robot platform migration requires mechanical redesign of end-of-arm tooling, full safety system revalidation, operator retraining, and production trial runs — a process that routinely takes 3 to 9 months and costs far more than the robot hardware itself. Maintaining the existing platform with verified spare parts is not a compromise; it is the operationally and financially rational choice for assets with remaining productive life.
Q: How do I know the unit is new or quality-refurbished?
A: Each unit is accompanied by an inspection report documenting the 5-step QA process described above. Condition grade (new surplus, tested refurbished, or pull-tested) is declared on the invoice. We do not ship units without a documented condition classification.
Q: Can you source other ABB IRB series discontinued parts?
A: Yes. DriveKNMS specializes in hard-to-find and discontinued industrial automation components across ABB, Fanuc, KUKA, Yaskawa, and other major robot and drive manufacturers. Contact us with your part number for availability.