
ABB NAMC-11C
ABB NAMC-11C is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.
RFQ-ready industrial model
Model: IRB460 3HAC037163-003 IRB 4602/33HAC037192-003 IRB66203HAC057980-004
Product Overview
Commercial availability is handled through direct RFQ, model verification and export-oriented follow-up rather than public cart checkout.
Datasheet Preview
Use attached product manuals when available. If the manual is not public yet, request the full file directly through RFQ.
Commercial Path
Product pages on DRIVEKNMS are designed to verify model, brand and series first, then move the buyer into one clean quotation path.
Technical Dossier
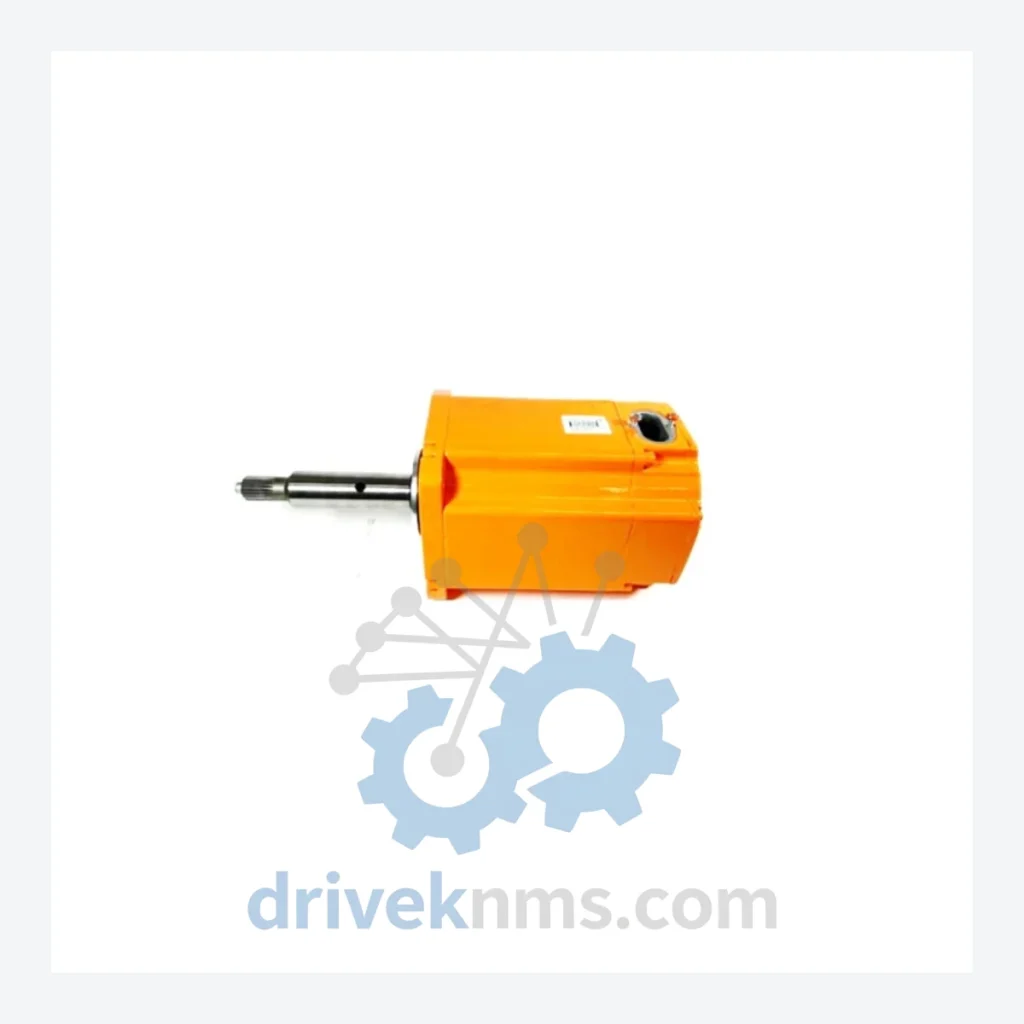
DriveKNMS holds RFQ-reviewed sourcing status of the ABB 3HAC037163-003 Motor incl Pinion, the OEM-specified axis drive component for the IRB460, IRB4602/33, and IRB6620 robot families. Securing this part today is not a maintenance expense. It is asset protection.
| Part Number | 3HAC037163-003 |
|---|---|
| Cross-Reference | 3HAC037192-003 / 3HAC057980-004 |
| Compatible Robot Models | ABB IRB460, IRB4602/33, IRB6620 |
| Component Type | Servo Motor with Integrated Pinion Gear |
| Manufacturer | ABB Robotics |
| Country of Origin | Sweden |
| Part Status | Hard-to-Find / Limited OEM Availability – Critical Spare |
| Application | Axis drive for industrial robot arm (palletizing, welding, material handling) |
Note: Electrical parameters (voltage, rated torque, encoder resolution) vary by robot axis assignment and are confirmed at order stage. No parameters are published here that cannot be verified against ABB documentation.
The ABB IRB460, IRB4602, and IRB6620 platforms represent a significant installed base across automotive, food & beverage, and heavy manufacturing. Many of these systems were commissioned in the 2005–2015 window and are now operating well past their original design lifecycle — not because they are inadequate, but because the cost of replacing them with current-generation robots (IRC5 or OmniCore controller migration, new end-of-arm tooling, full re-programming, and safety re-validation) is prohibitive.
Q: How are RFQ terms confirmed?
A: Quantity, required condition, documentation needs, destination and sourcing route are confirmed during RFQ review before quotation.
For plant managers and maintenance engineers facing pressure to justify continued operation of IRB460 or IRB6620 installations rather than capital expenditure on new equipment, the following framework has been applied successfully across multiple facilities:
3. Implement condition-based monitoring on motor temperature and vibration. ABB's IRC5 controller logs axis current draw data that can be trended to identify motor degradation before failure. This data is available without additional hardware investment on most installations.
Applied consistently, this approach has allowed facilities to extend the productive life of IRB460 and IRB6620 installations by 5–10 years beyond the point at which OEM support becomes unreliable — deferring capital expenditure while maintaining production throughput.
Every unit of 3HAC037163-003 processed through DriveKNMS undergoes a structured 5-stage inspection protocol before dispatch:
Stage 1 – Visual and Mechanical Inspection: Housing integrity, connector condition, and pinion gear tooth profile are examined. Units with corrosion on electrical pins or visible mechanical damage to the pinion are rejected at this stage.
Stage 3 – Firmware and Encoder Verification: Where applicable, encoder signal integrity is verified. Firmware version is documented and confirmed against ABB's compatibility matrix for the target robot model.
Stage 5 – Functional Documentation: Each unit is dispatched with a condition report documenting inspection findings, part number verification, and serial number (where present). This documentation supports traceability requirements in regulated manufacturing environments.
Drop-in replacement: The 3HAC037163-003 is an OEM part number. Installation follows ABB's standard axis motor replacement procedure. No mechanical adaptation, no custom mounting, no re-engineering of the robot cell.
No controller re-programming required: The IRC5 controller identifies the motor through the SMB (Serial Measurement Board) system. A correctly installed OEM motor does not require parameter changes or software modification to the robot program. Production resumes from the point of interruption.
Avoids engineering reconstruction costs: The alternative to sourcing a compatible spare motor is a forced migration to a current-generation ABB robot platform. This involves new controller hardware, full re-programming of robot paths and I/O, end-of-arm tooling re-validation, and safety system re-certification. Conservative estimates for a single robot cell migration start at USD 80,000–150,000 and extend upward depending on integration complexity. A spare motor eliminates this exposure entirely.
Q: How do I confirm this is a genuine or quality-verified unit, not a counterfeit?
A: All units are sourced through documented supply chains. Part number markings, housing construction, and connector specifications are verified against ABB reference documentation. A condition report is provided with each unit. We do not dispatch units that fail any stage of our 5-step inspection protocol.
Q: Can you support multi-unit or repeat RFQ requests?
A: Yes. Send the model list, target quantity and destination so DRIVEKNMS can review sourcing options and quote the requirement as a project RFQ.
Continue The Model Path
Move from this exact model into the matching system hub, brand archive, model-family archive or lifecycle sourcing route before sending a final RFQ list.
Related Paths
ABB NAMC-11C is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.
ABB LZ02 is listed for H&B Contronic LZ Series RFQ review. Confirm quantity, condition and destination before quotation.
ABB LL02 is listed for Controller Cards RFQ review. Confirm quantity, condition and destination before quotation.